A planar four-bar linkage mechanism with 3 revolute kinematic pairs and 1 prismatic kinematic pair is shown in the figure, where AB ⊥ CE and FD ⊥ CE. The T-shaped link CDEF is constructed such that the slider B can cross the point D, and CE is sufficiently long. For the given lengths as shown, the mechanism is
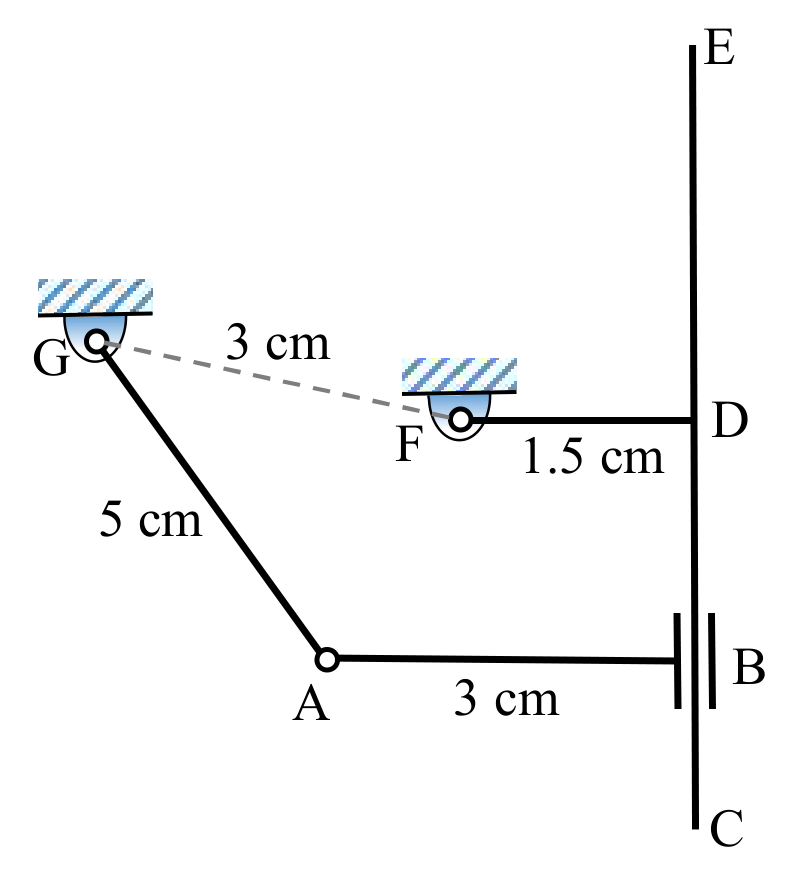
- Aa Grashof chain with links AG, AB, and CDEF completely rotatable about the ground link FG
- Ba non-Grashof chain with all oscillating links
- Ca Grashof chain with AB completely rotatable about the ground link FG, and oscillatory links AG and CDEF
- Don the border of Grashof and non-Grashof chains with uncertain configuration(s)